Project · Active since Jan 2025
OSRC
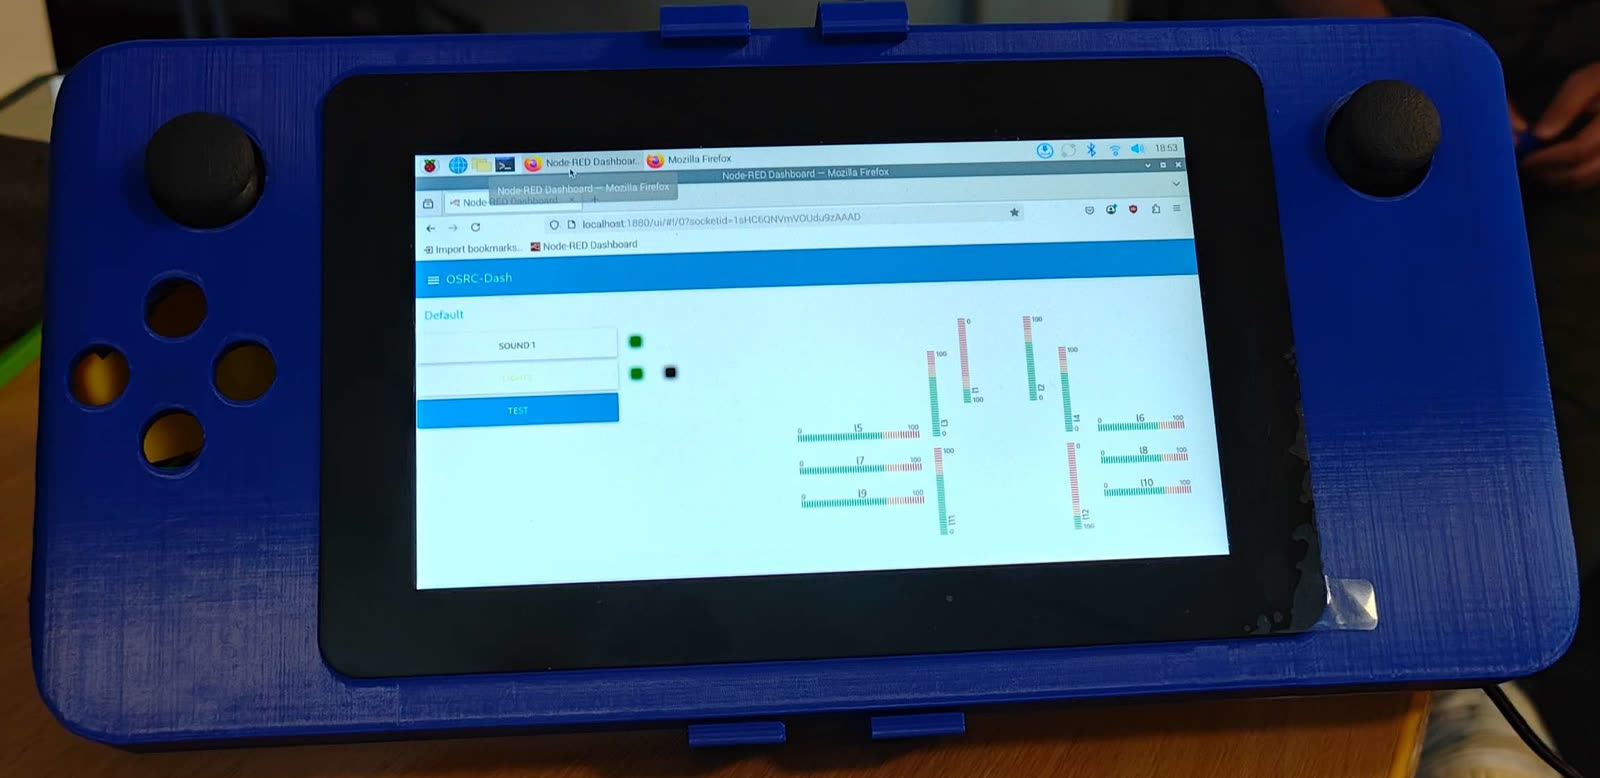
The Open Source Robotics Controller, a fully 3D-printed handheld remote for any robot that speaks ROS, ROS 2 or MQTT.
Overview
Robot control usually means a laptop, a gamepad and a lot of cables. We wanted one portable, standalone remote that any student or researcher could build and adapt.
The OSRC runs on a Raspberry Pi 5 with a 7-inch touchscreen. A Teensy 3.6 reads the dual joysticks and buttons with low latency, and the enclosure is designed in CAD and printed in-house. Node-RED and MQTT let it drive robots over the local network.
Build log
- Connecting robots with Node-RED Sending controller inputs to robots over the local network with MQTT.
- First trials Driving a ROS rover and a ROS 2 drone with the OSRC, and what we improved.
- Installing ROS and ROS 2 Setting up Ubuntu, ROS and ROS 2 on the Raspberry Pi and mapping the controls.
- Designing and printing the case An ergonomic, modular enclosure designed in CAD and printed in PLA+ and PETG.
- Inside the OSRC The Raspberry Pi 5, Teensy, joysticks and touchscreen that make up the controller.
- Introducing the OSRC Our open-source robot remote: Raspberry Pi 5, 7-inch touchscreen and dual joysticks, fully 3D printed.
Explore the CAD
Parts straight from our GitHub repository. Drag to turn a part around and pick another from the row below.
New parts appear here automatically when their STL files are added to the repository.